

G Kishor
Final Year Student at Sri Krishna College Of Engineering And Technology
- Coimbatore, Tamil Nadu, India
- kishoratwork5@gmail.com
- +91-9489313399
Dynamic and creative CAD designer passionate about innovation. Experienced with graphics and mechanical design, plus expertise in industry-standard software. Seeking internship to collaborate with teams, build upon existing design skills and create innovative solutions to design problems.
Projects
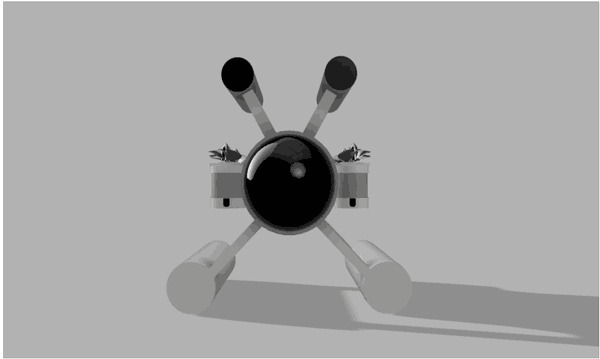
design and fabrication of an aquatic rover for inspection of head race tunnel.
- solidworks
- fusion 360
- arduino programming
- machine learning
- blender
- autocad
- Design and fabricate a remotely operated vehicle for the inspection of head race tunnels in Hydro Electric plant using machine learning.
- Proposed solution has the potential to revolutionize the inspection process for the Head Race Tunnel in Hydro-electric plants, reducing downtime and minimizing the risk of damage to the plant. The development of this project represents a significant contribution to the field of inspection technology and has practical applications in the renewable energy sector.
- The Head Race Tunnel, which is a critical component of a Hydro-electric plant, plays a crucial role in conveying water from the reservoir to the turbines. Ensuring the Head Race Tunnel is operating efficiently and effectively is crucial to the optimal operation of the entire plant.
- Traditional inspection methods for the tunnel are often timeconsuming, expensive, and pose a safety risk to personnel.To address these challenges, new inspection methods utilizing advanced technologies such as Drone technology and Machine Learning algorithms have been proposed.
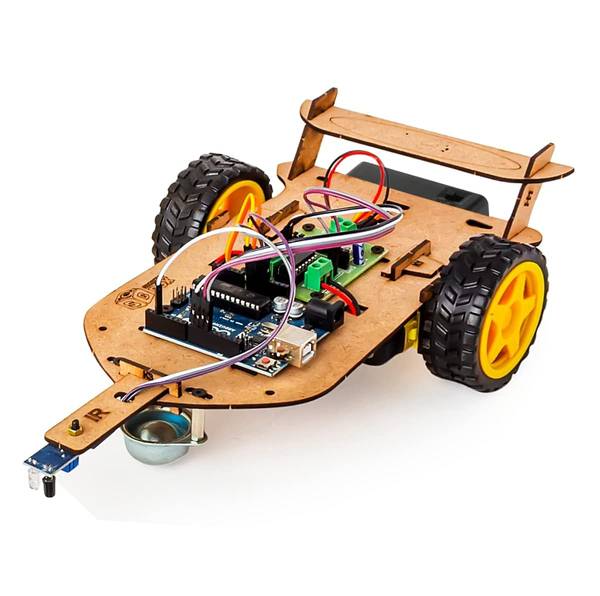
arduino-based edge avoiding robot
- arduino programming
- solidworks
- Edge avoiding robot is a kind of very simple robot that simply detect the edges by some sensor.
- The edge-avoiding smart robot works like when any sensor detects the edge the robot will turn according to the sensor direction. It means if the right side sensor comes near the edge then the Arduino robot will make a turn in the opposite direction which is the left side 7 vice-versa.
I have made this robot for fun and learning purposes only. Also. To learn a lot of things from this robot such as [programming](https://techatronic.com/category/arduino-tutorial/), connection, and Sensor working. The main purpose to make this robot is to learn the working and basic concepts.